Projects
Things I have built
A selection of projects from more than a decade of hands-on engineering, from competition robots, a Mars rover prototype and DUET's first flying drone to industrial automation and full-stack web applications.
Web Development · 2026 – Present
raselrana.com.bd — Personal Website and Content Platform
My professional home on the web: a full-stack Next.js platform with a private dashboard that manages every page, image and document on the site, joined to a separate technical blog.
- Next.js
- React
- Tailwind CSS
- MongoDB
- Cloudinary
- Resend
- Framer Motion
- Vercel
- Cloudflare
Robotics · 2016
BD Martian-1 — Mars Rover for the University Rover Challenge
A next-generation Mars rover prototype built by Team DUET TimeOut for the University Rover Challenge, the world's leading robotics competition for student-built planetary rovers. The team qualified for the URC 2017 final in Utah, USA, as one of around 30 teams selected worldwide.
- Robotics
- Mars Rover
- Embedded Systems
- Motor Control
- Wireless Control
Robotics · 2015 – 2017
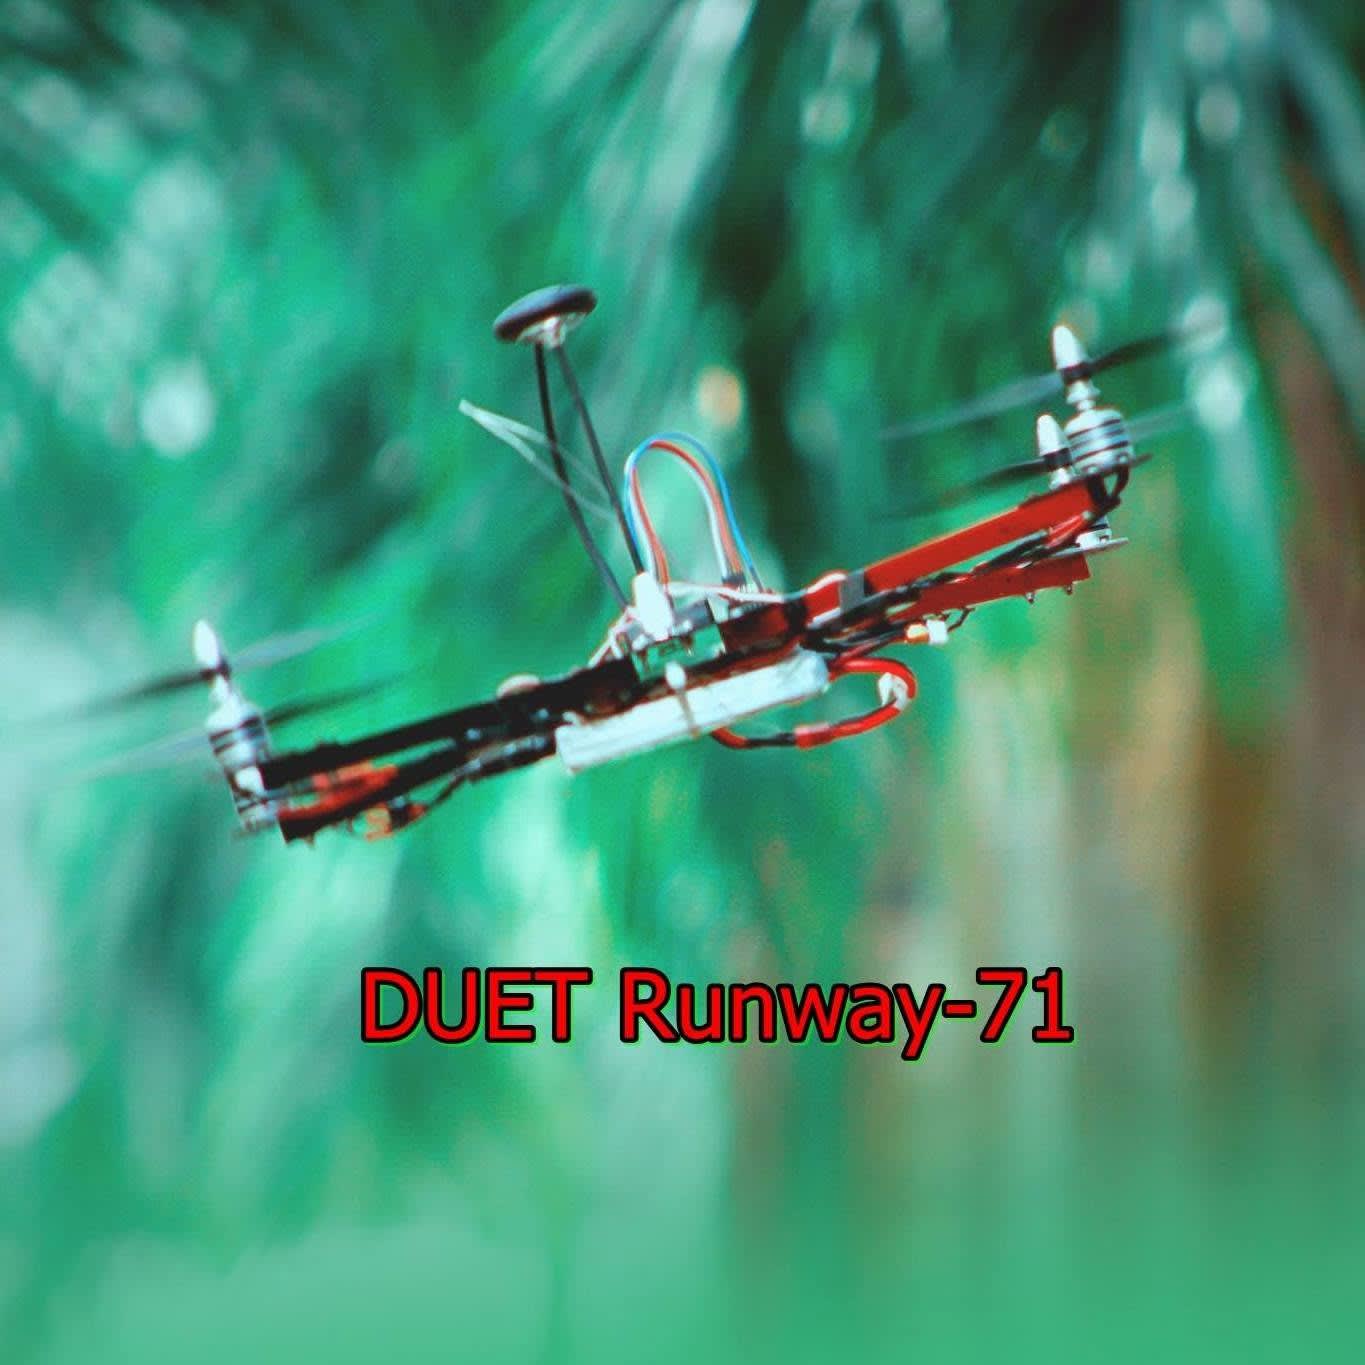
Multirotor Drone Design and Control — DUET's First Flying Drone
A self-funded quadcopter designed, built and tuned from scratch by Team DUET Runway-71, which I founded and led. On 11 August 2017, it made the first successful drone flight in DUET's history.
- Drones
- Flight Control
- brushless motors
- GPS
Robotics · 2016
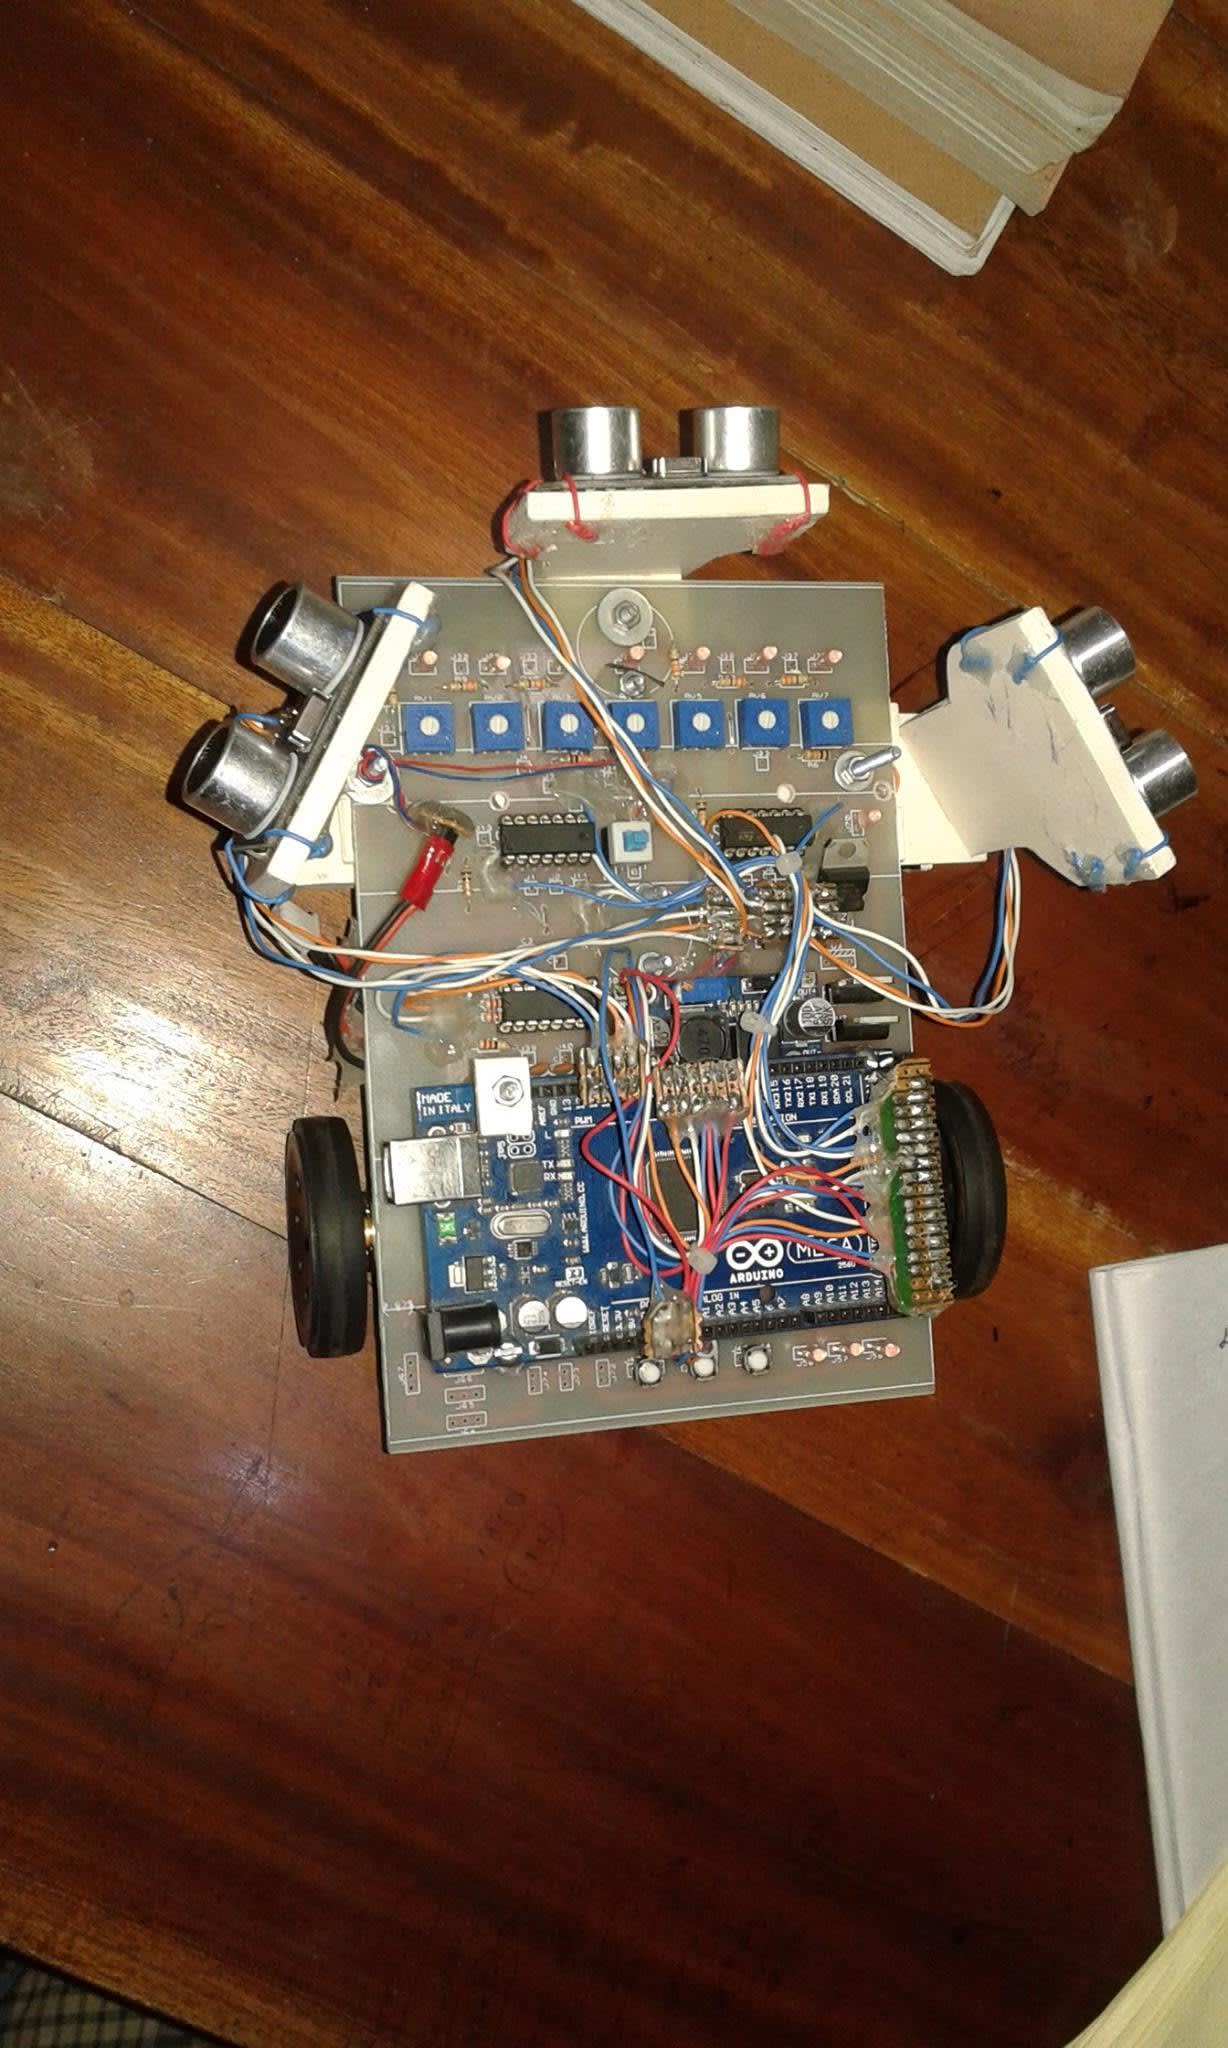
Title: Line Follower and Maze-Solving Robot
A compact autonomous robot that Team DUET Robo Express designed and built entirely in-house, from circuit design and simulation to a hand-made PCB, soldering, programming and tuning. It won 2nd Runner-up at the Global Robotics Challenge 2016, the IARC Bangladesh Zonal round.
- Autonomous Robots
- Arduino
- PCB Design
- Proteus
- Embedded Systems
- Sensors

Research · 2017 – 2018
Comparative Analysis of Control Techniques for High-Speed Mechatronic Systems
My B.Sc. thesis at DUET: a simulation study comparing five feedback control techniques for high-speed nanopositioning systems, an atomic force microscope (AFM) and a piezoelectric tube scanner (PZT). We designed and tuned each controller in MATLAB and Simulink, then compared their stability, speed, damping and tracking to find the best controller for each system.
- Control Systems
- MATLAB
- Simulink
- Nanopositioning
- Controller Design
Industrial Automation · 2017
Conveyor Control with Siemens LOGO PLC
A university project that automates a conveyor belt with a Siemens LOGO PLC, using inductive proximity and capacitive sensors to detect items on the belt and control the motor automatically. It recreated, on a small scale, the sensor-driven material handling used on production lines across industry.
- PLC
- Siemens LOGO
- Industrial Automation
- Proximity Sensors
- Motor Control
Industrial Automation · 2016
Star-Delta Motor Starter (Contactor and PLC Versions)
A university project that builds a star-delta starter for a three-phase induction motor in two versions: a conventional design with magnetic contactors and a timer, and an automated version controlled by a Siemens LOGO PLC. Comparing the two showed how PLC-based control replaces fixed wiring with flexible, programmable logic.
- Motor Control
- PLC
- Siemens LOGO
- Electrical Systems
- Industrial Automation
Industrial Automation · 2017
Motor Speed Control with a Variable Frequency Drive and Siemens LOGO PLC
A university project that controls an induction motor's speed, direction, acceleration and deceleration through a variable frequency drive (VFD), automated by a Siemens LOGO PLC. It showed how the PLC-and-VFD combination used across modern industry gives smooth, efficient and programmable motor control.
- VFD
- PLC
- Siemens LOGO
- Motor Control
- Industrial Automation